The Assignment
Testing and validating LiDAR sensors requires the ability to evaluate sensor performance across different scenarios and operating conditions.
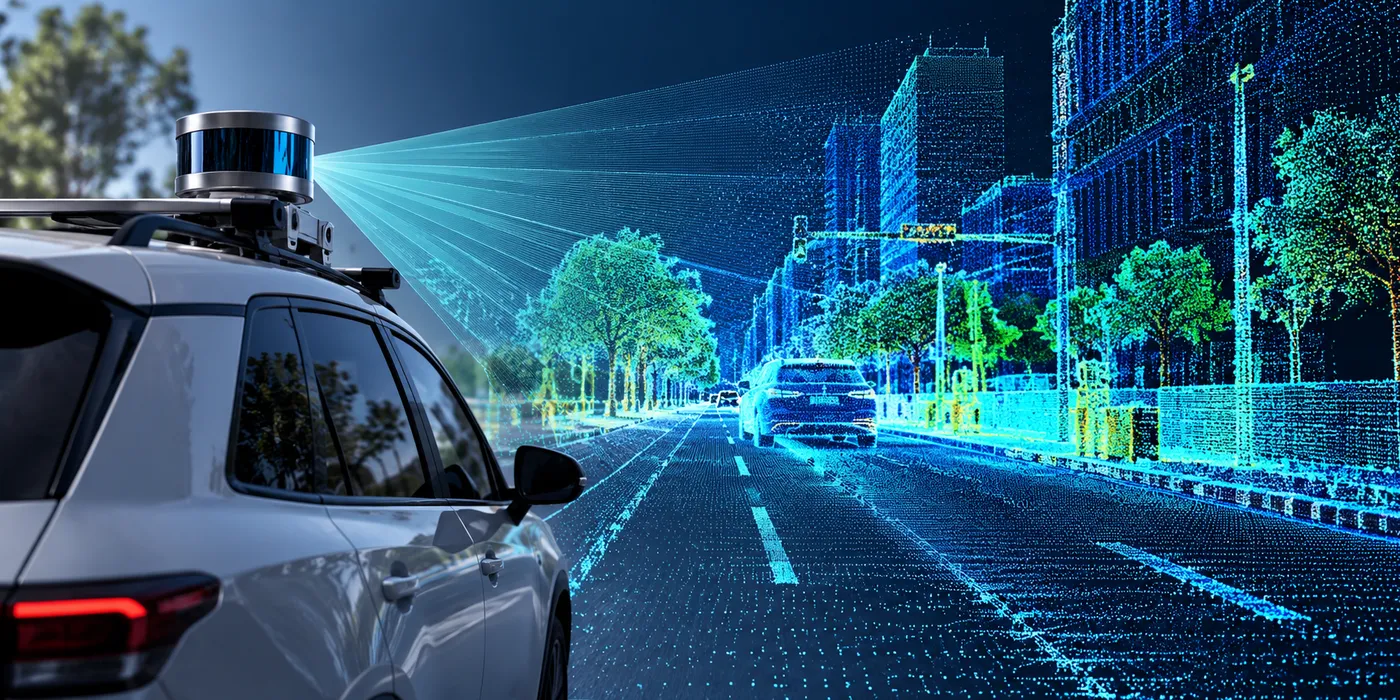
CS TECH Ai developed a proof-of-concept LiDAR sensor digital twin for a major sensor manufacturing company. The objective was to create a virtual environment in which different sensor testing and validation scenarios could be explored using a digital representation of the sensor and generated point-cloud data.
Our Approach
CS TECH Ai created a LiDAR sensor digital twin within NVIDIA Omniverse and generated point-cloud data to support testing and validation scenarios.
The proof of concept brought the sensor and its simulated 3D environment together, providing a digital framework for exploring how LiDAR sensor behaviour and resulting point-cloud information could be evaluated virtually.
The approach included:
- Creation of a LiDAR sensor digital twin
- Development within NVIDIA Omniverse
- Generation of point-cloud data
- Creation of virtual testing scenarios
- Support for sensor testing and validation
Technology & Delivery
The proof of concept combined LiDAR, 3D point-cloud generation, digital-twin technology and NVIDIA Omniverse within a virtual testing environment.
The resulting workflow provided a structured approach:
LiDAR Sensor → Digital Twin → Virtual Environment → Generated Point Cloud → Testing & Validation
This demonstrated how digital-twin technology could be applied to support sensor engineering and validation workflows.